Forgot to post this on the 10/4-New CAD
Again rubbish quality due to limit on file sizes - to small for HD video's
The original blogspot blog, written for ICT homework to log building and programming a line following robot. Being cloned across to this site.
Created using Tailwind CSS and Claude.
Again rubbish quality due to limit on file sizes - to small for HD video's
Finished.
---As usual I used HTML to increase the video size and used a downgraded video quality so that it can be uploaded.
I showed the teacher and he showed me that the fixed wheels would be a problem. I've came up with a solution which I am not sure Roger would like. (However If I get time [more than last time] - which is very unlikely - I will make an even more detailed CAD of my new design)
The scans aren't done yet.
I am in the process of making a CAD of the robot.
Here are the beginnings of what was going to be our data cable: Our analogue (6 choice) light->light sensor, master-slave 'data cable'. However we have decided to now use the NXT Bluetooth functionality: which like our light-sensor'data cable' would be a master-slave conection
The movie is saved as widescreen but all components have been optimized for standard. I have also used the blogger's HTML function to increase the size of the video so it may be a bit problematic
Since the last post the blog has looked weird - I do not know why - I do now.
I'm changing the title by taking of the 'ICT' bit.
It doesn't Use the Jump Break/'Read more' properly so some posts like the previous ones are cut off with out using the 'read more' text
That's all this post is for.
The last lot of entries was a web log for our ICT project (in my pair was Ju-Hyeok and myself); This has had to be ended as we are now doing something else in our ICT lessons. But I go to robotics club and Roger and I are making a linefollwer with three light sensors. Later I will post scans of some of my plans and sketches, and maybe even some snippets of programming and other extra's, so stay tuned.
PS. The club is on Fridays
PPS. We may be helped or more likely be competing against Ju-Hyeok in beating this other group's record (in our school-Whitgift).
Today (5March2012) we decided to end our project with the following programming:
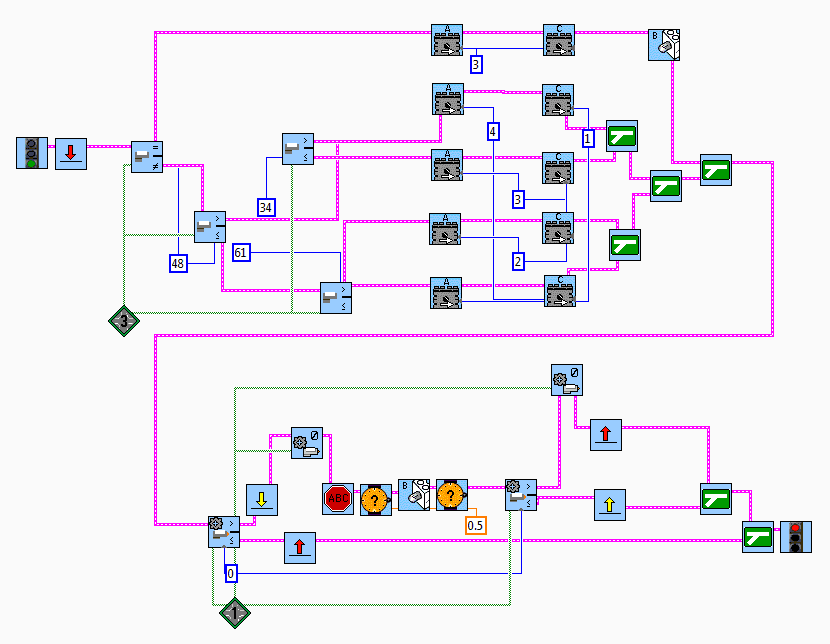
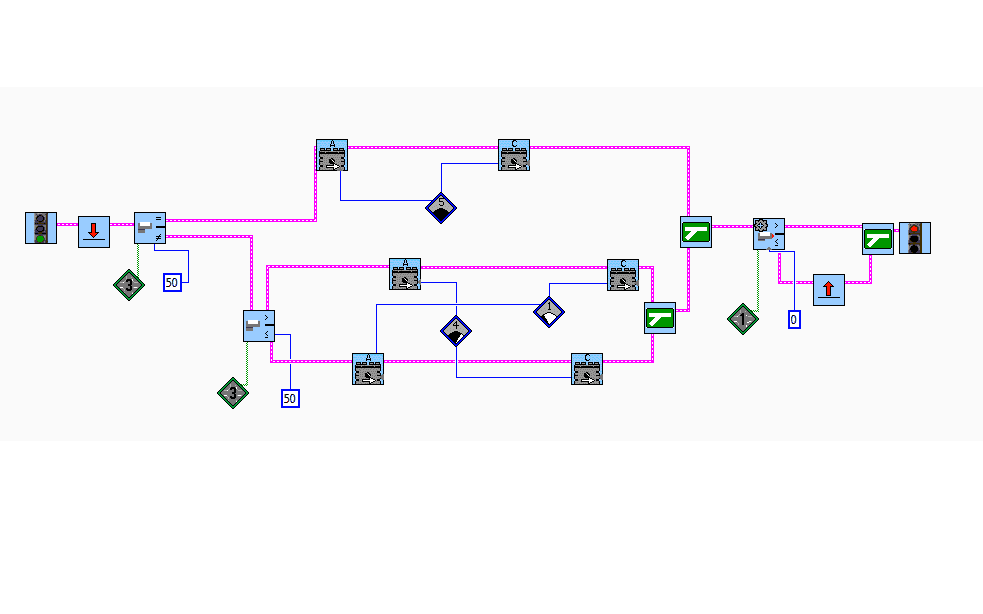
This is the whole program.
For the individual parts...
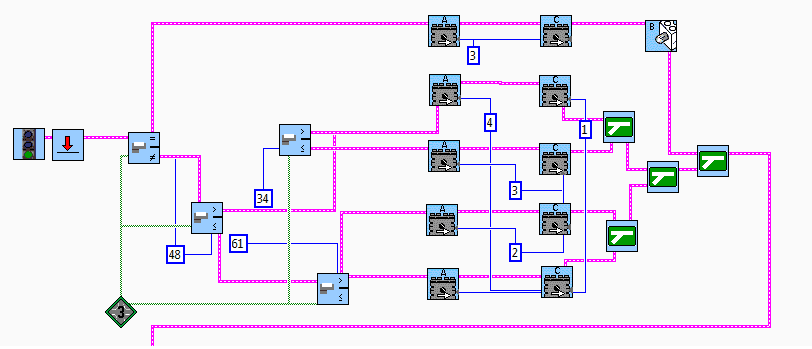
This is the part which actually moves the robot. It is a five speed/turn ratio program.
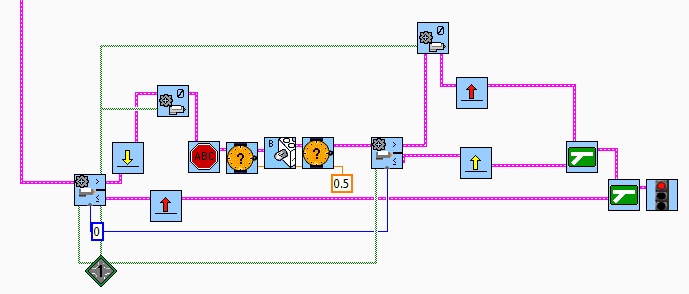
This part is the pause/play switch - the part which probably makes our buggy the most unique in the whole class.
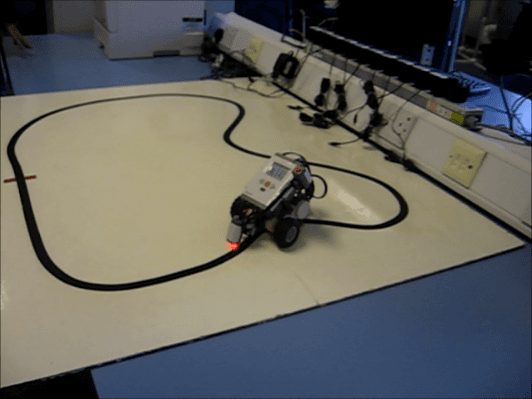
We were on Monday thinking about bring the project to a close on Friday, with our fine tuned inventor programming. However ...
...we gave it a quick run (which kept having problems (unlike on Monday) and was the second slowest of our robots at 18.68) and had a peek at a friends almost seamless,straight running. So we decided to continue and fine tune it even further.
here is a picture of the first fine tune programming and a frame of the robot (taken from a movie (shown)).
If we can I wish to:
In the last two lessons we explored Inventor programming and made our first inventor program for our robot. It took our robot 18.81 seconds to complete the lap (slower than the more simple pilot programming-which however was also less controlled)
In the last two lessons we have been programming and running our buggy. In the very last level we took videos. We have chosen the best programming which still has some faults, although it can complete a lap in 14.56seconds and do up to 6 consecutve laps before ''spinning out''.
The video is extremely low quality so that it could be uploaded so don't full screen it (unless you don't care).
We have used the booklet to make a robot and filmed us making it. However we had a few problems.
First of all the camera kept turning off (it had to many video's already on it) and we were missing a few pieces of equipment. Here is the video:
So far we have learnt the basic functions of the NXT and the program. Next we shall make and program a line following 'buggy'; using a booklet.